GNSS HAT Library Documentation
Key Features
- Multi-language API - C++, C, Python
- UBX protocol oriented - NAV-PVT, NAV-SAT, NAV-DOP, MON-RF, NAV-GEOFENCE, TIM-TM2 + many more supported OOTB, any other required msg can be added easily
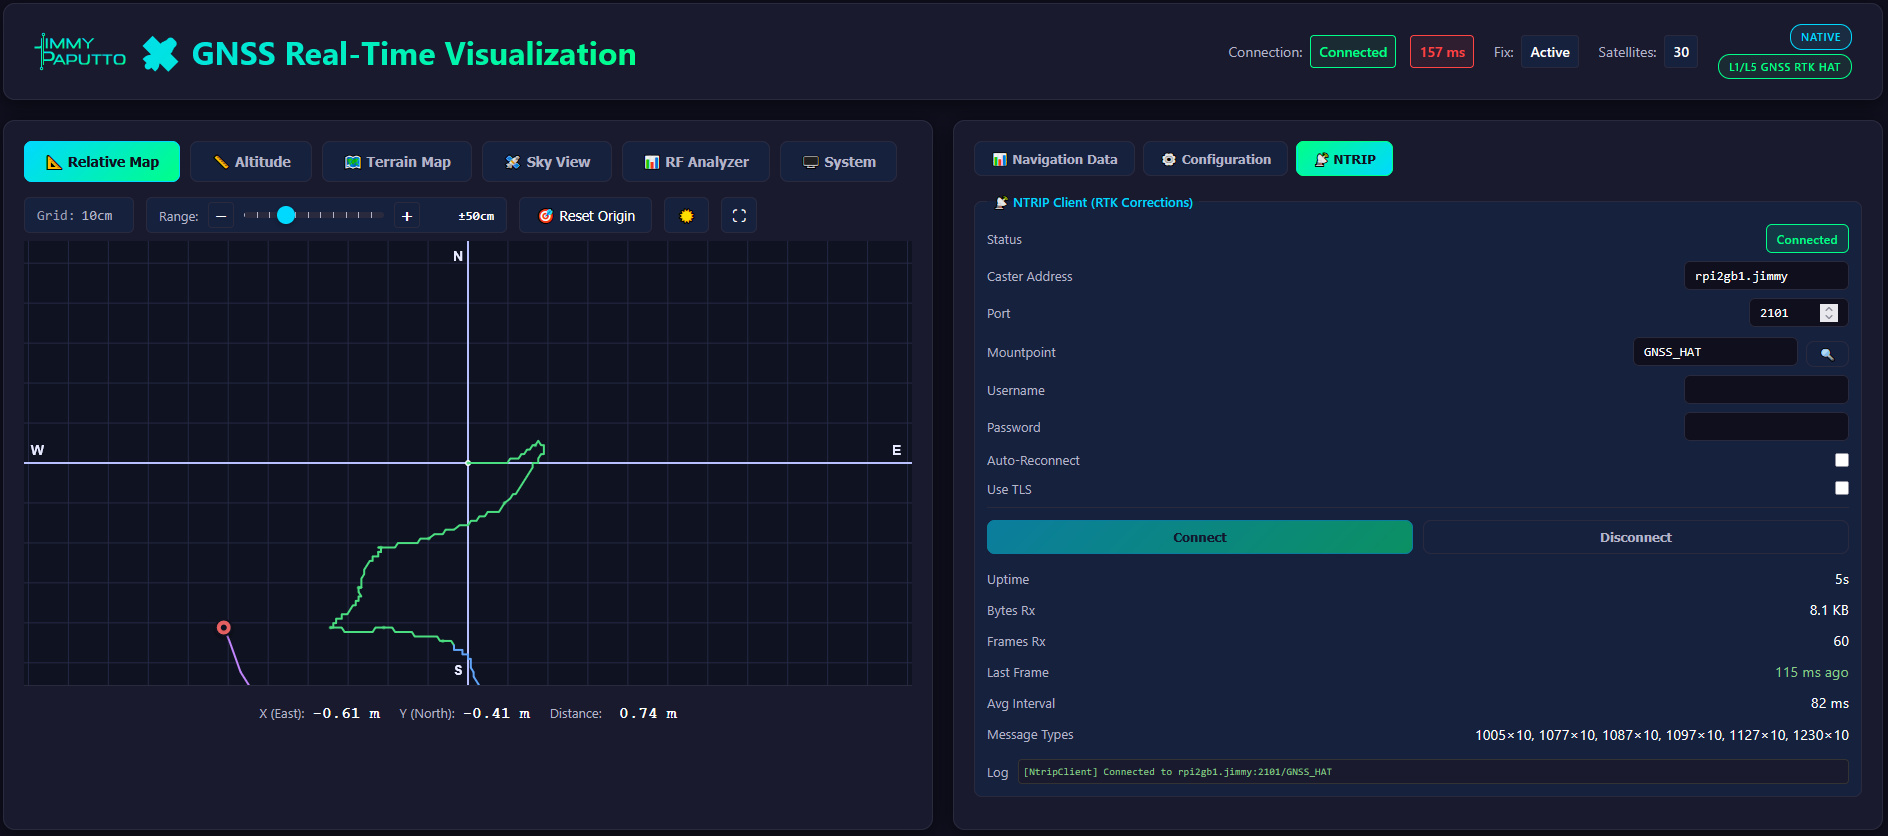
- RTK support - centimeter-level positioning with RTCM3 base/rover corrections just in few lines of code
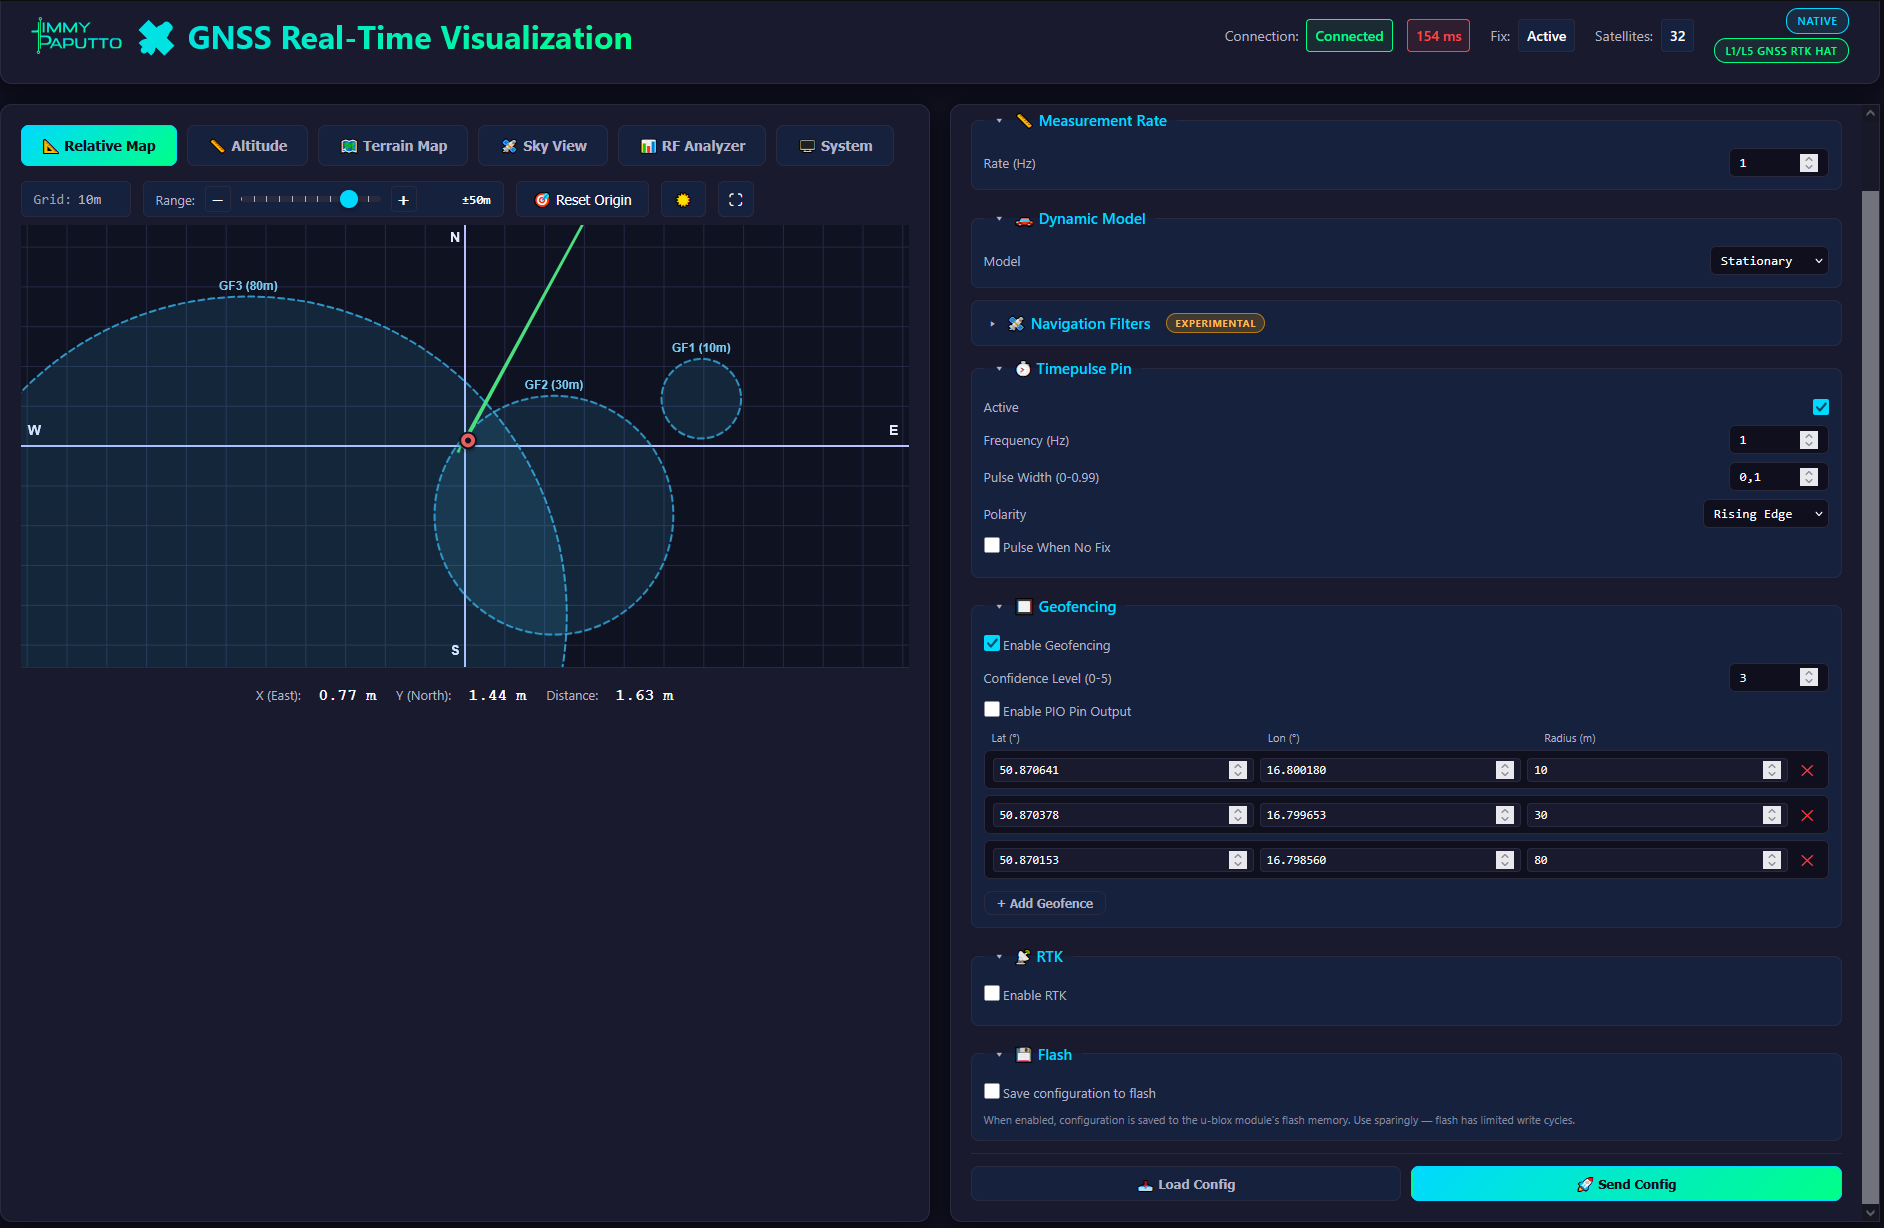
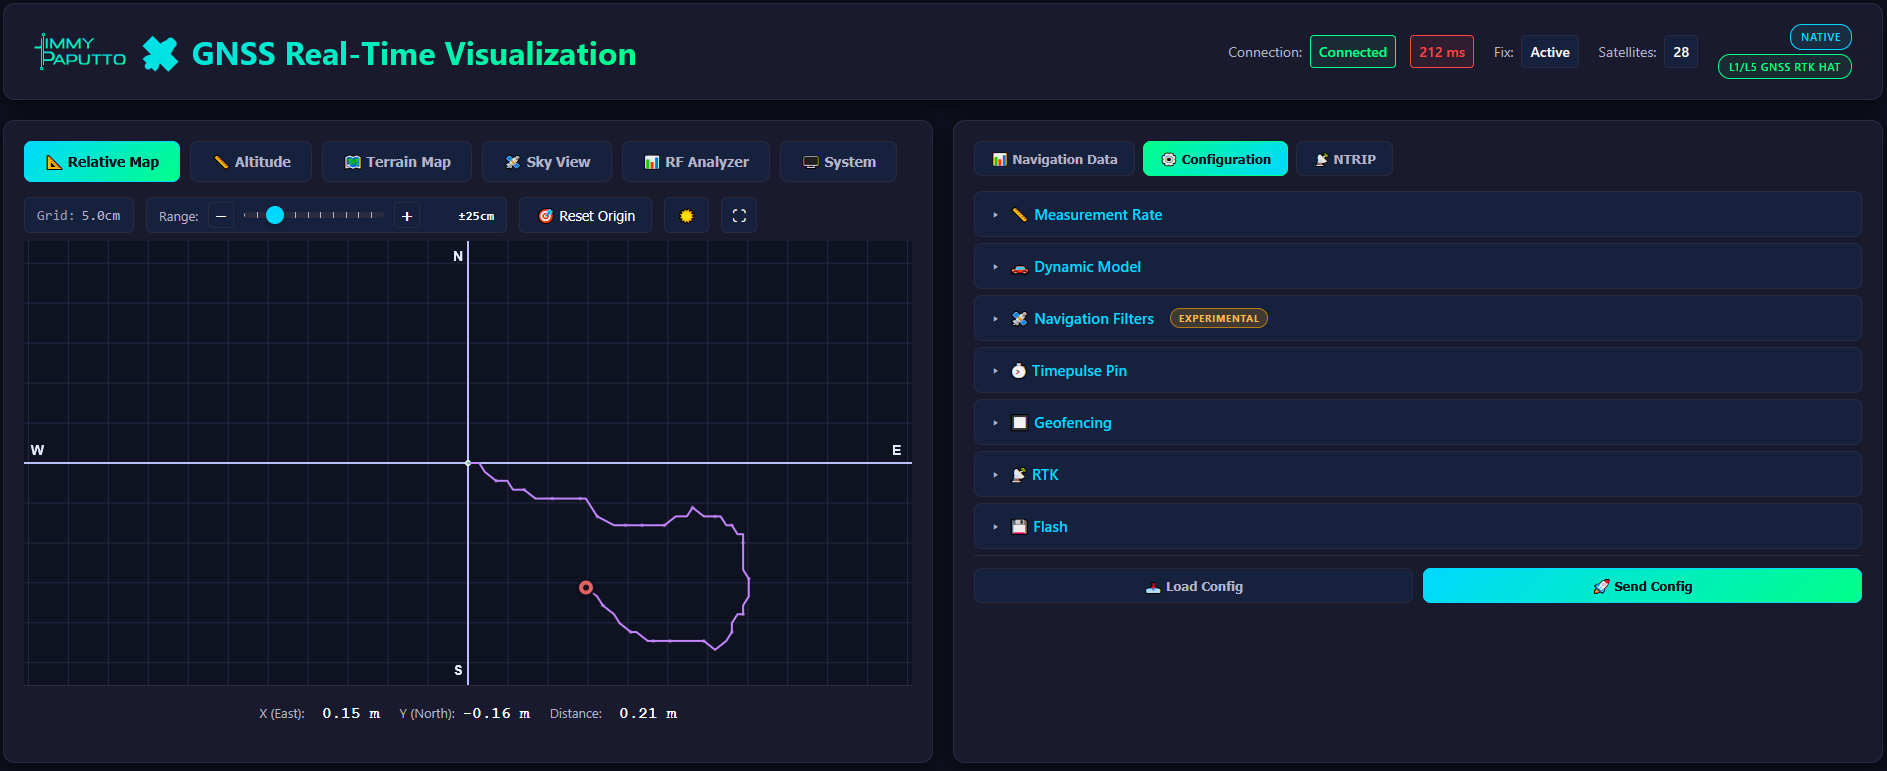
- Geofencing - up to 4 circural zones with configurable hardware relay and state connected to geofences status
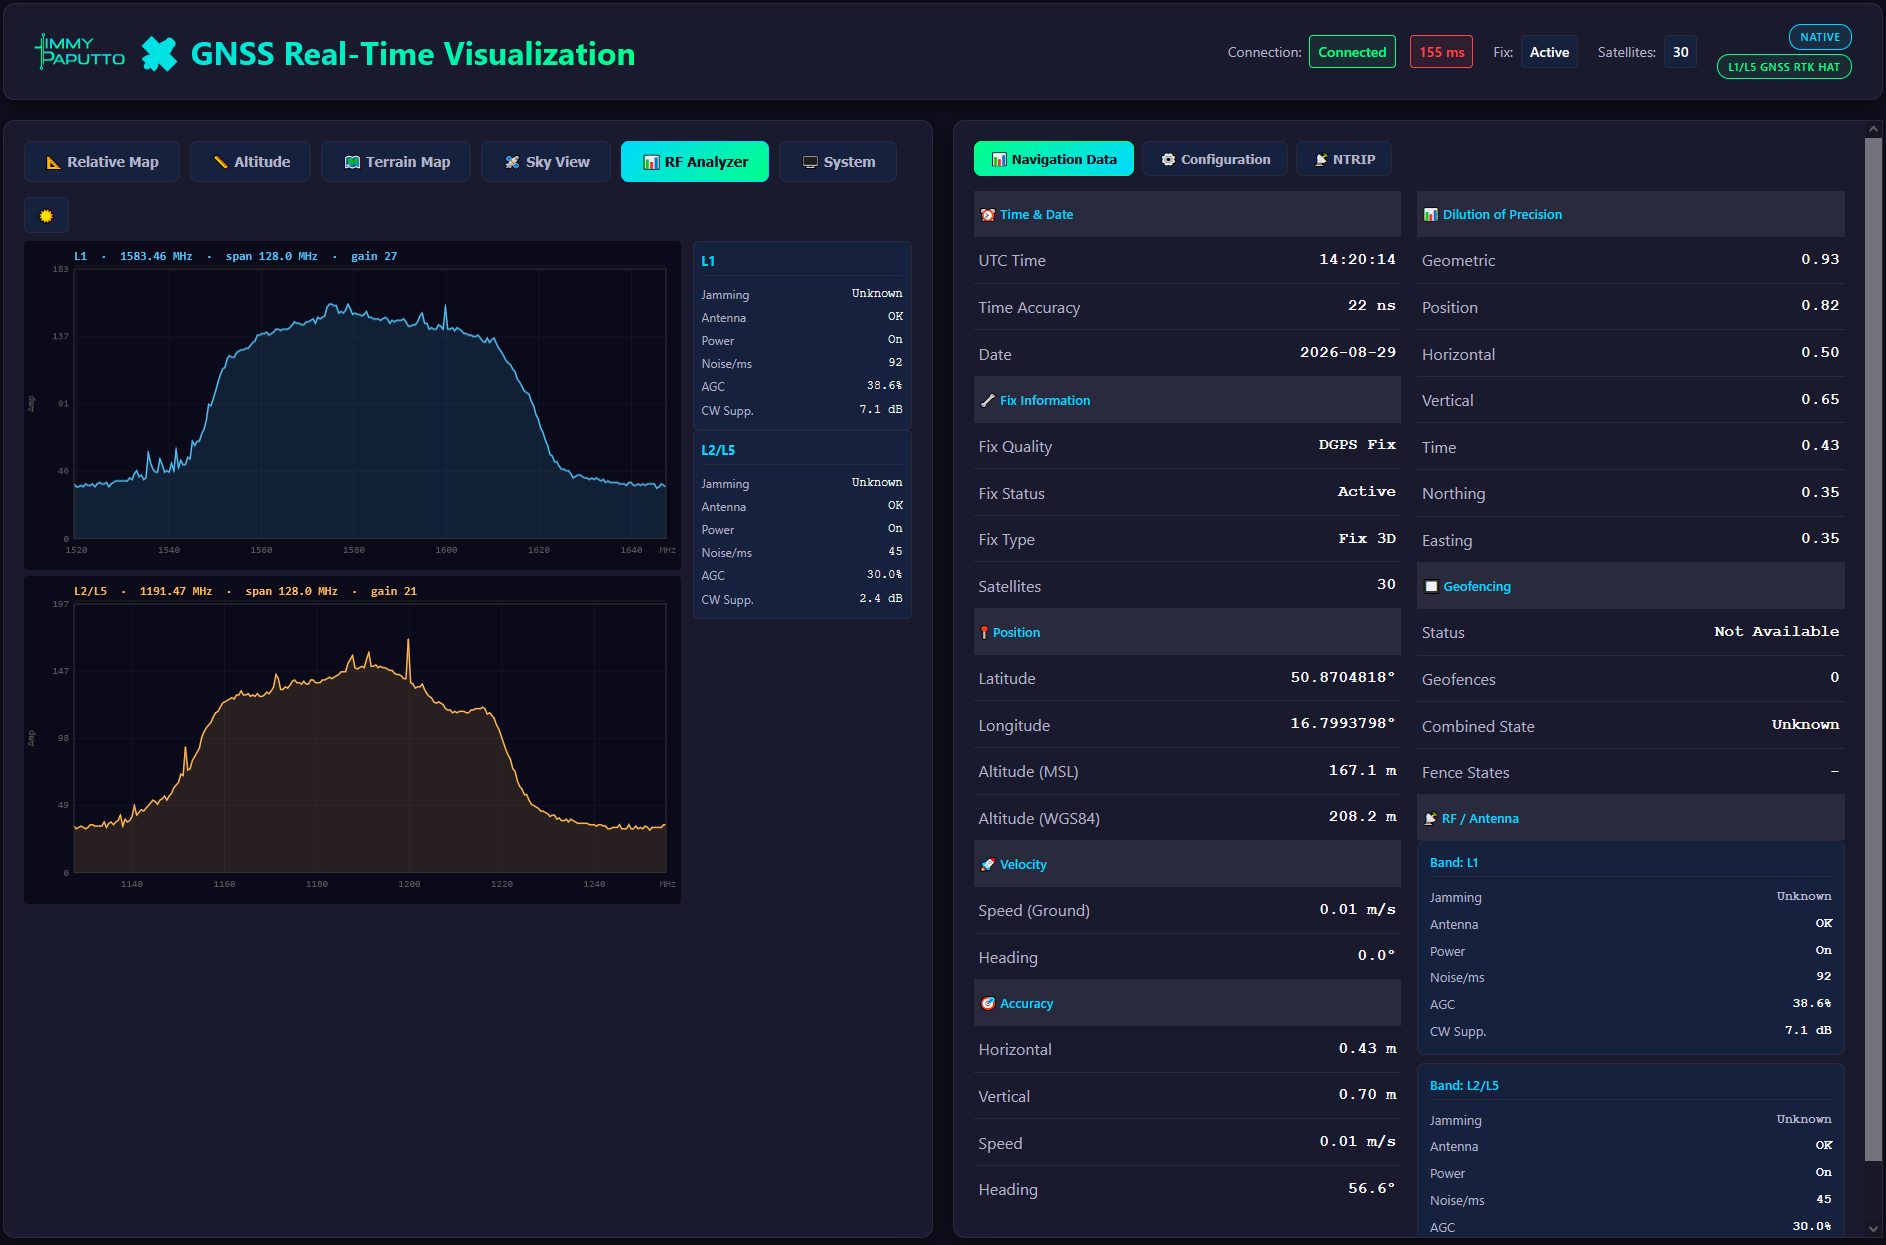
- Jamming detection - per-band RF interference monitoring
- GPSD integration - NMEA forwarding to virtual serial port for any legacy implementation
- Thread-safe - event-driven, no busy-wait loops
- 1–25 Hz measurement rate (depends on configuration and hardware)
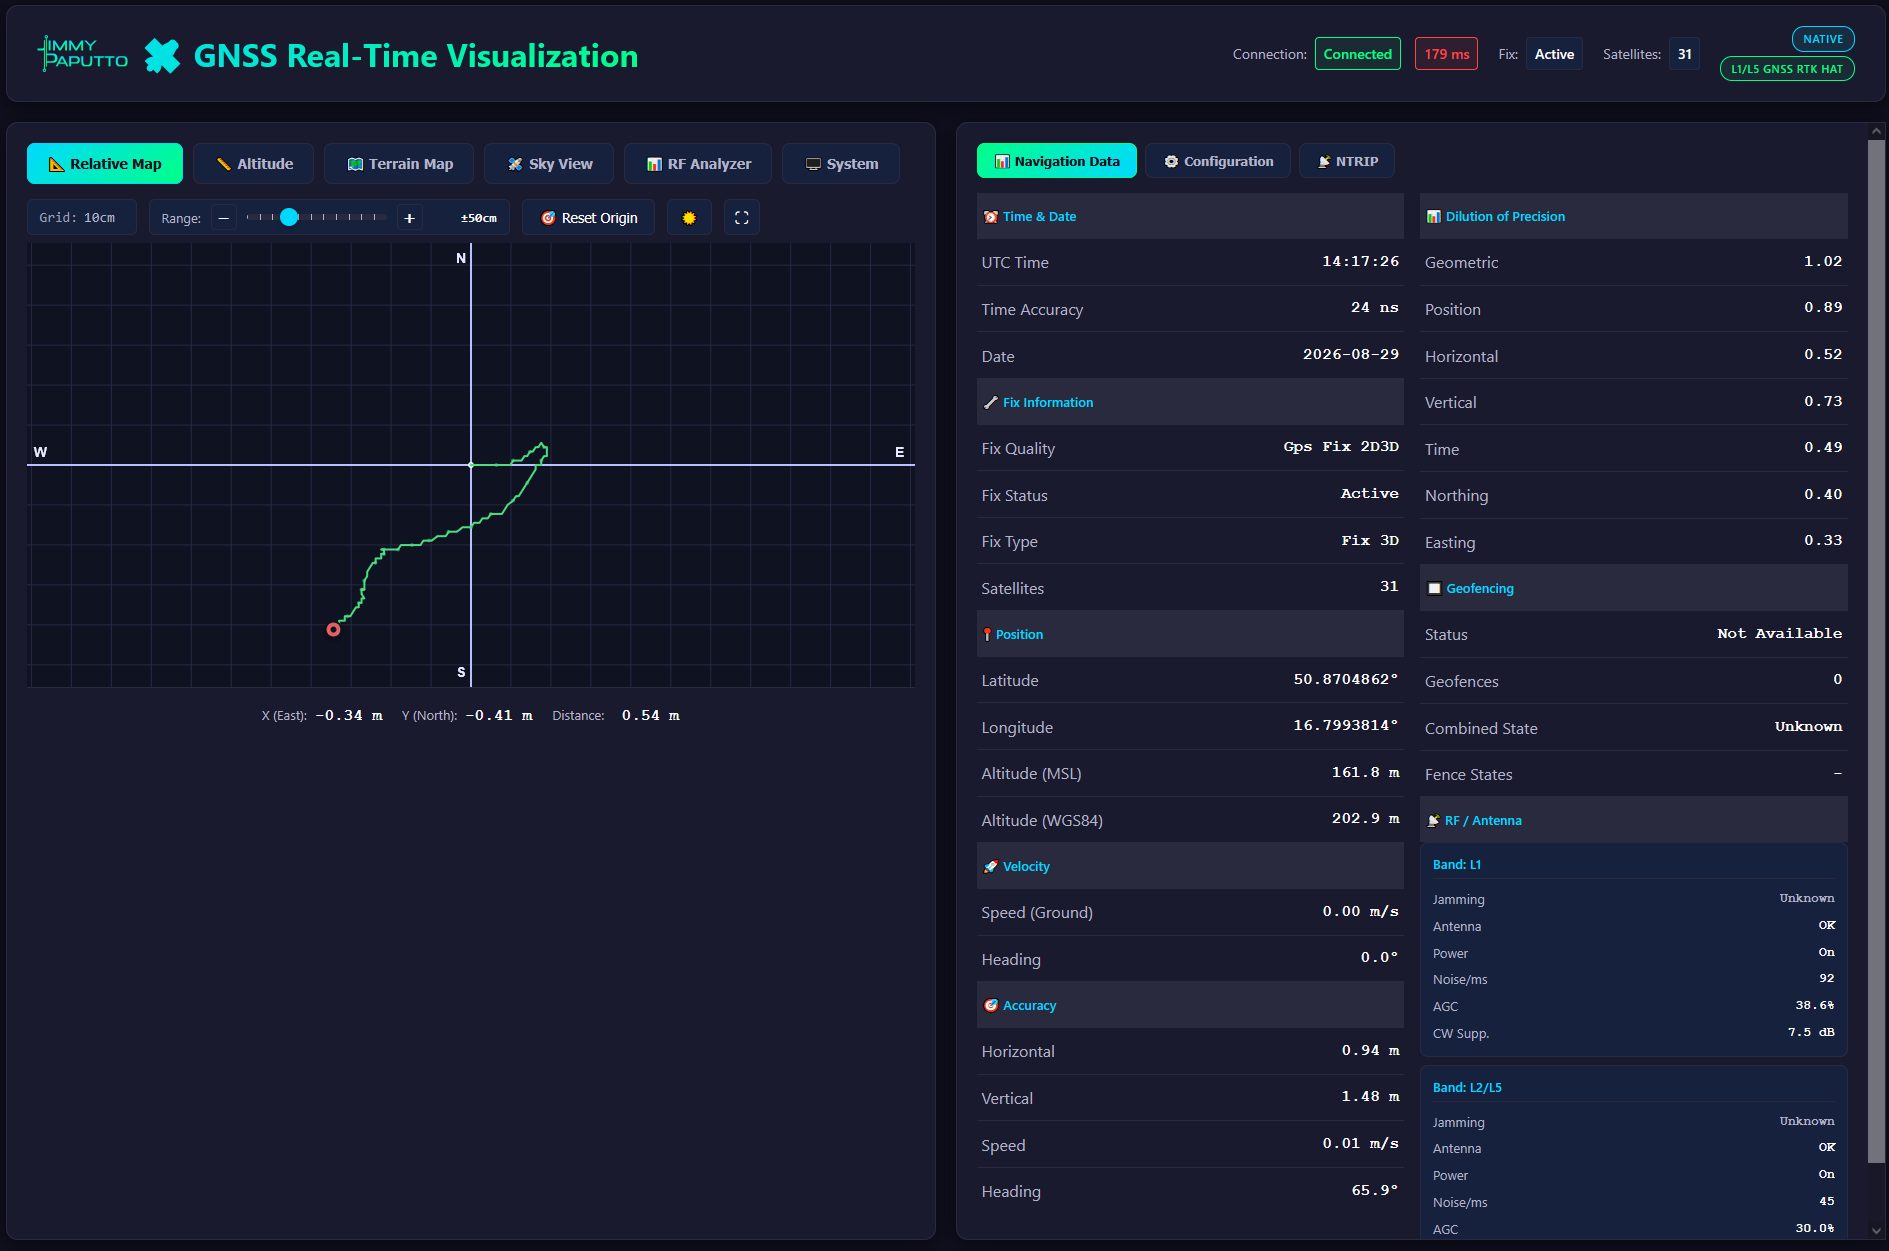
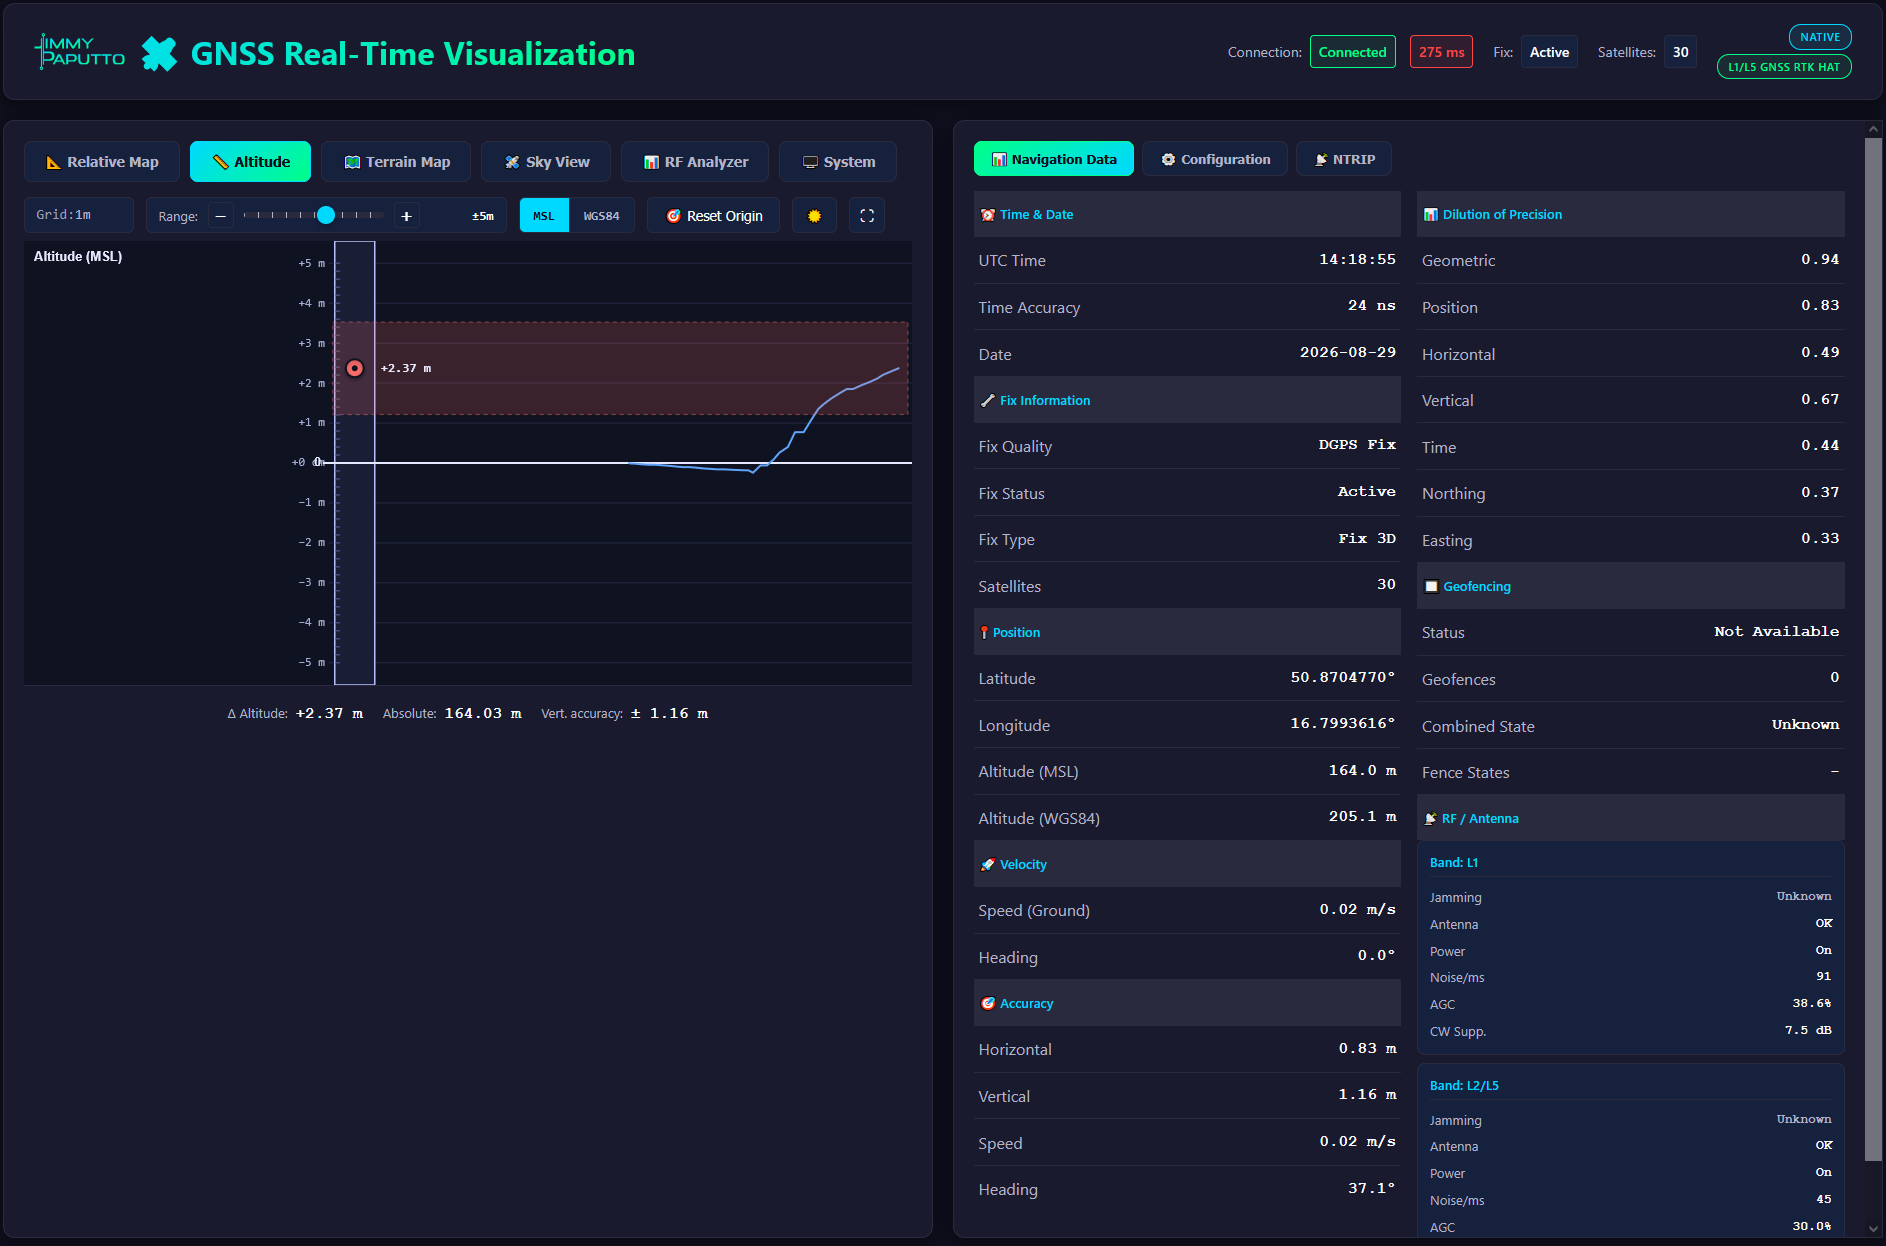
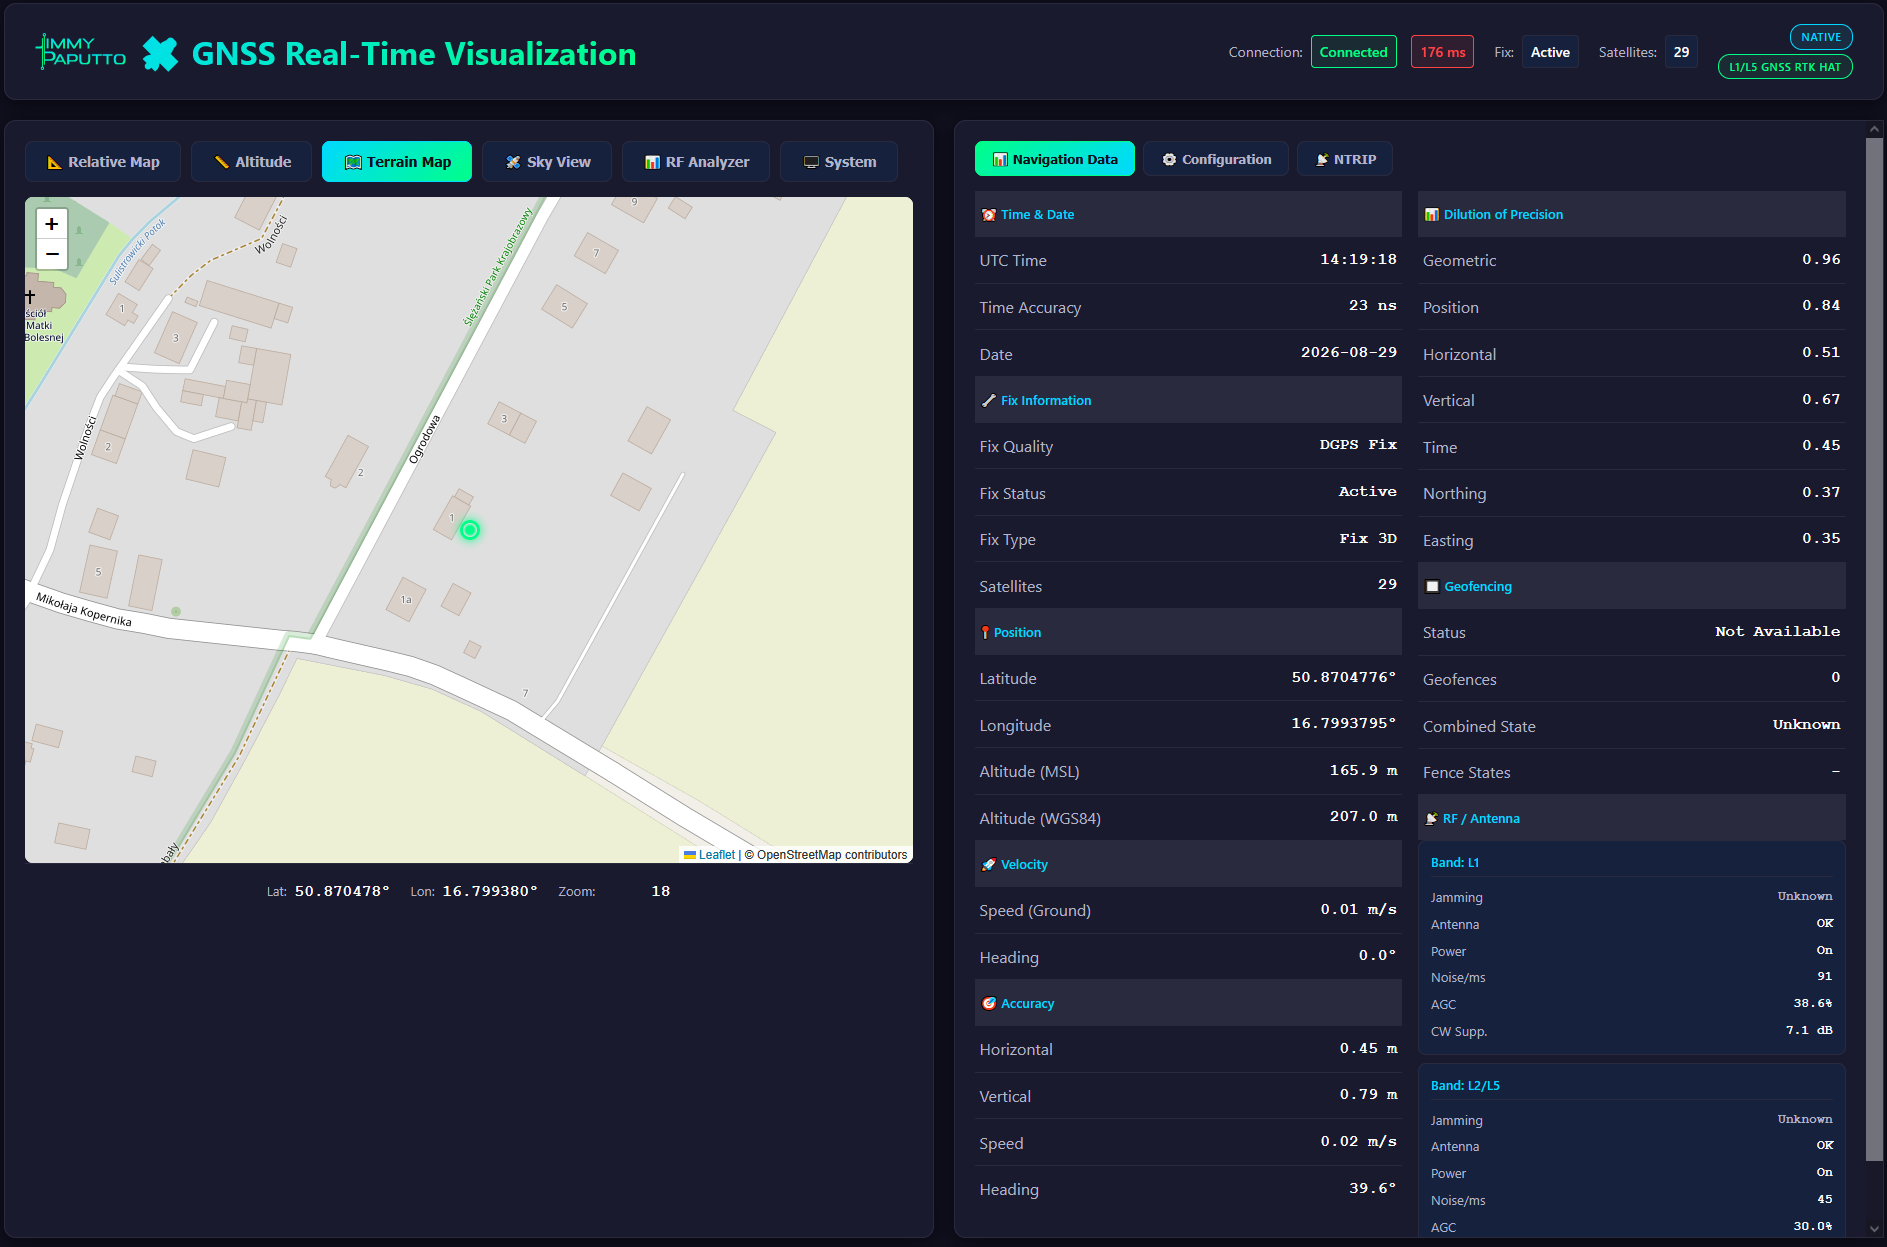
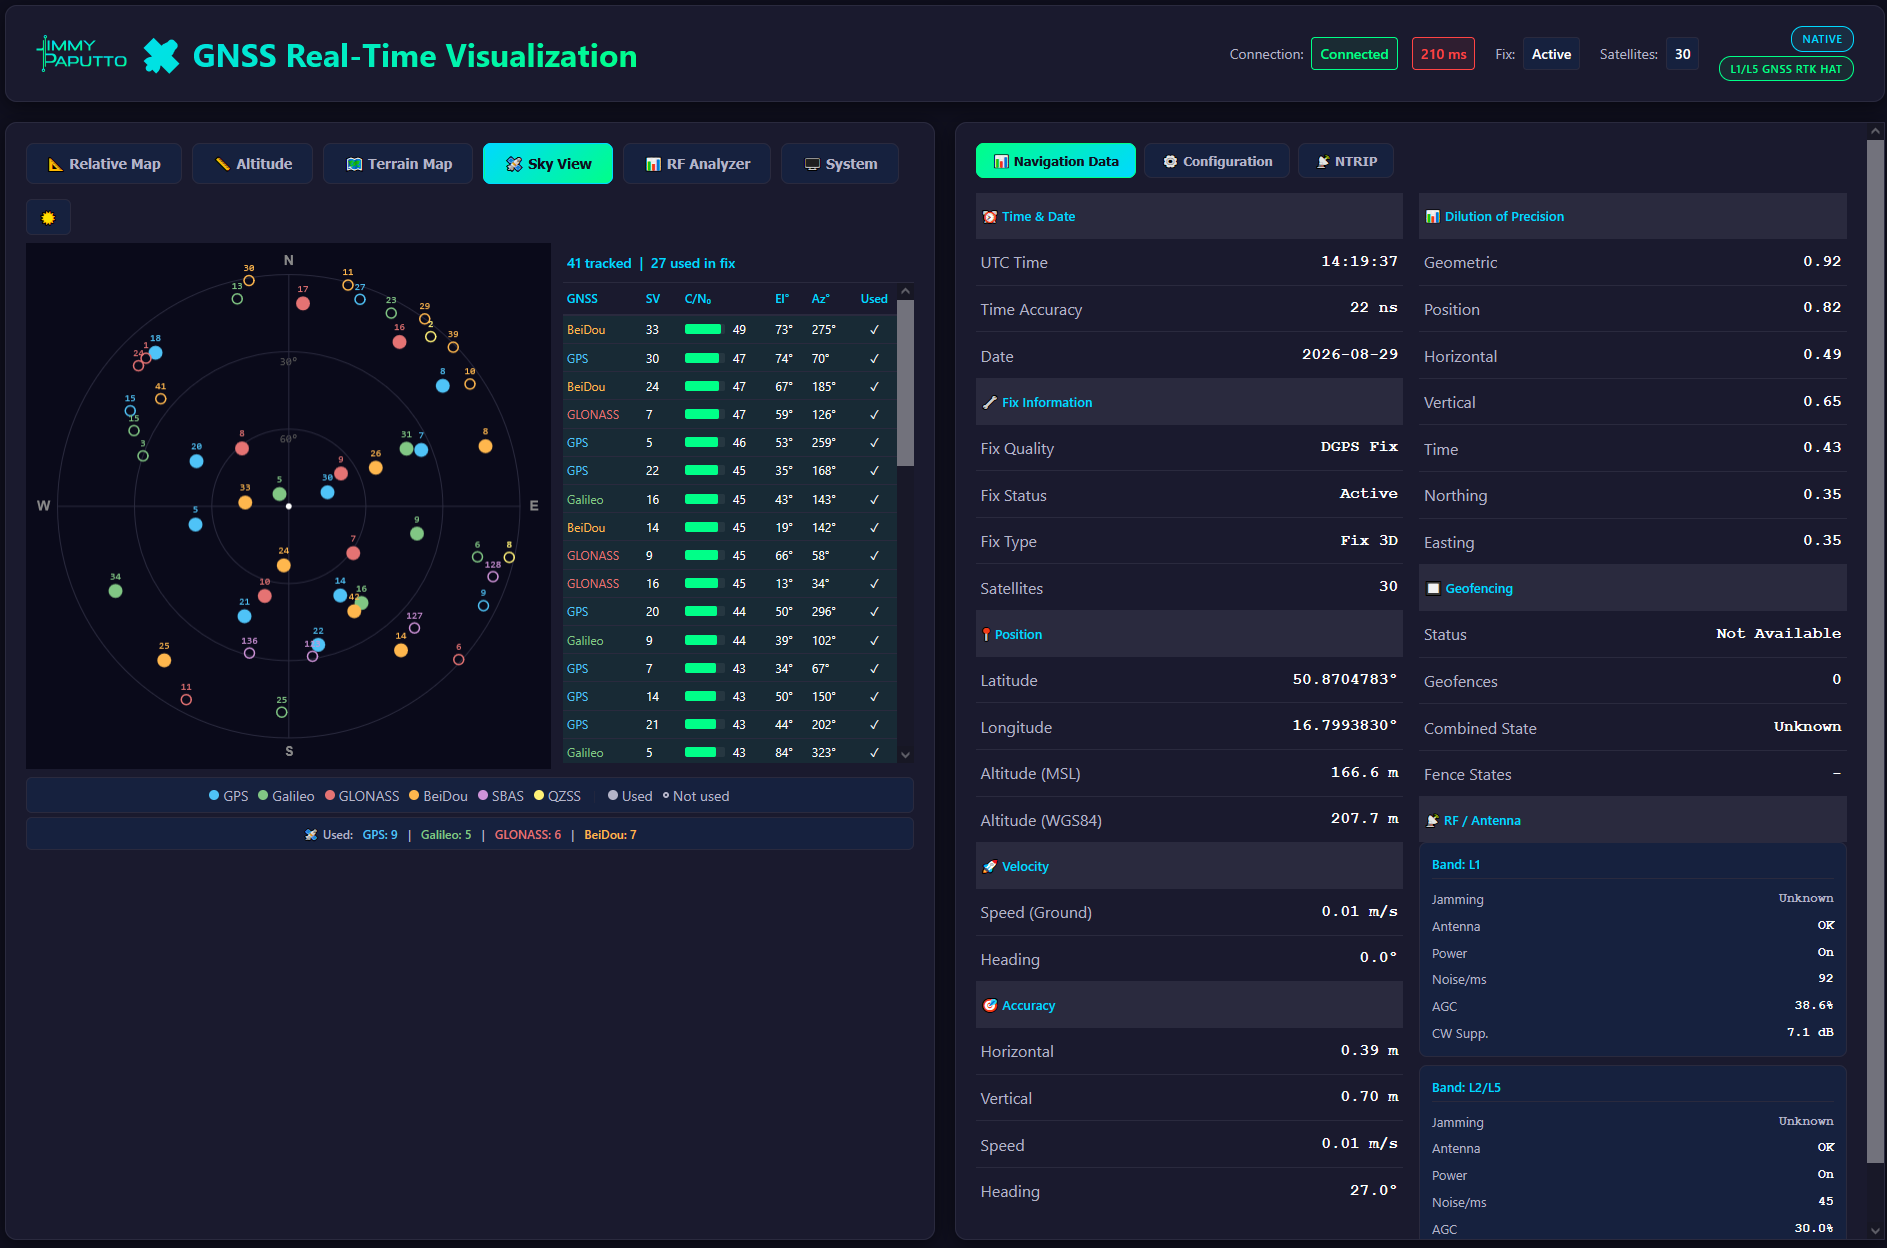
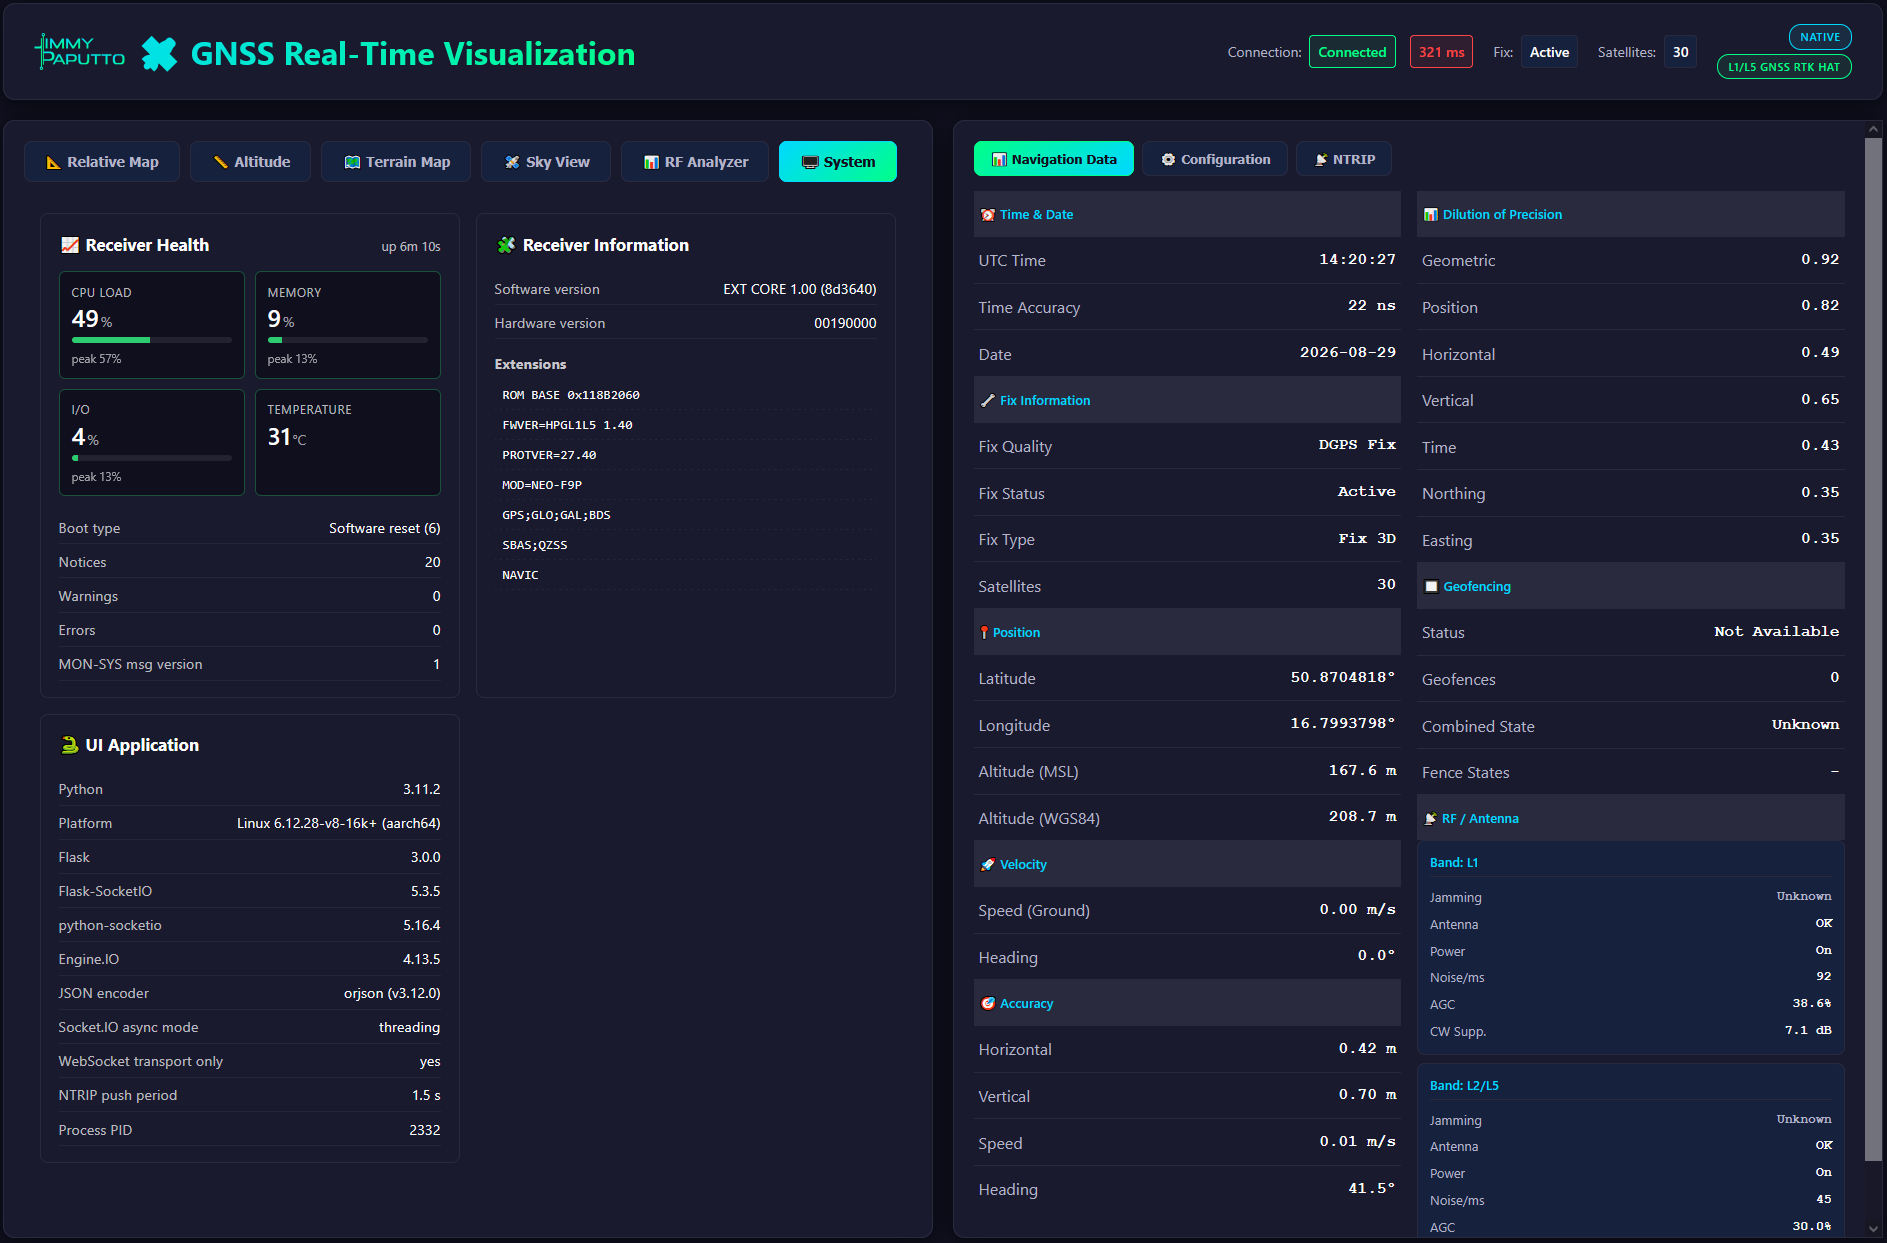
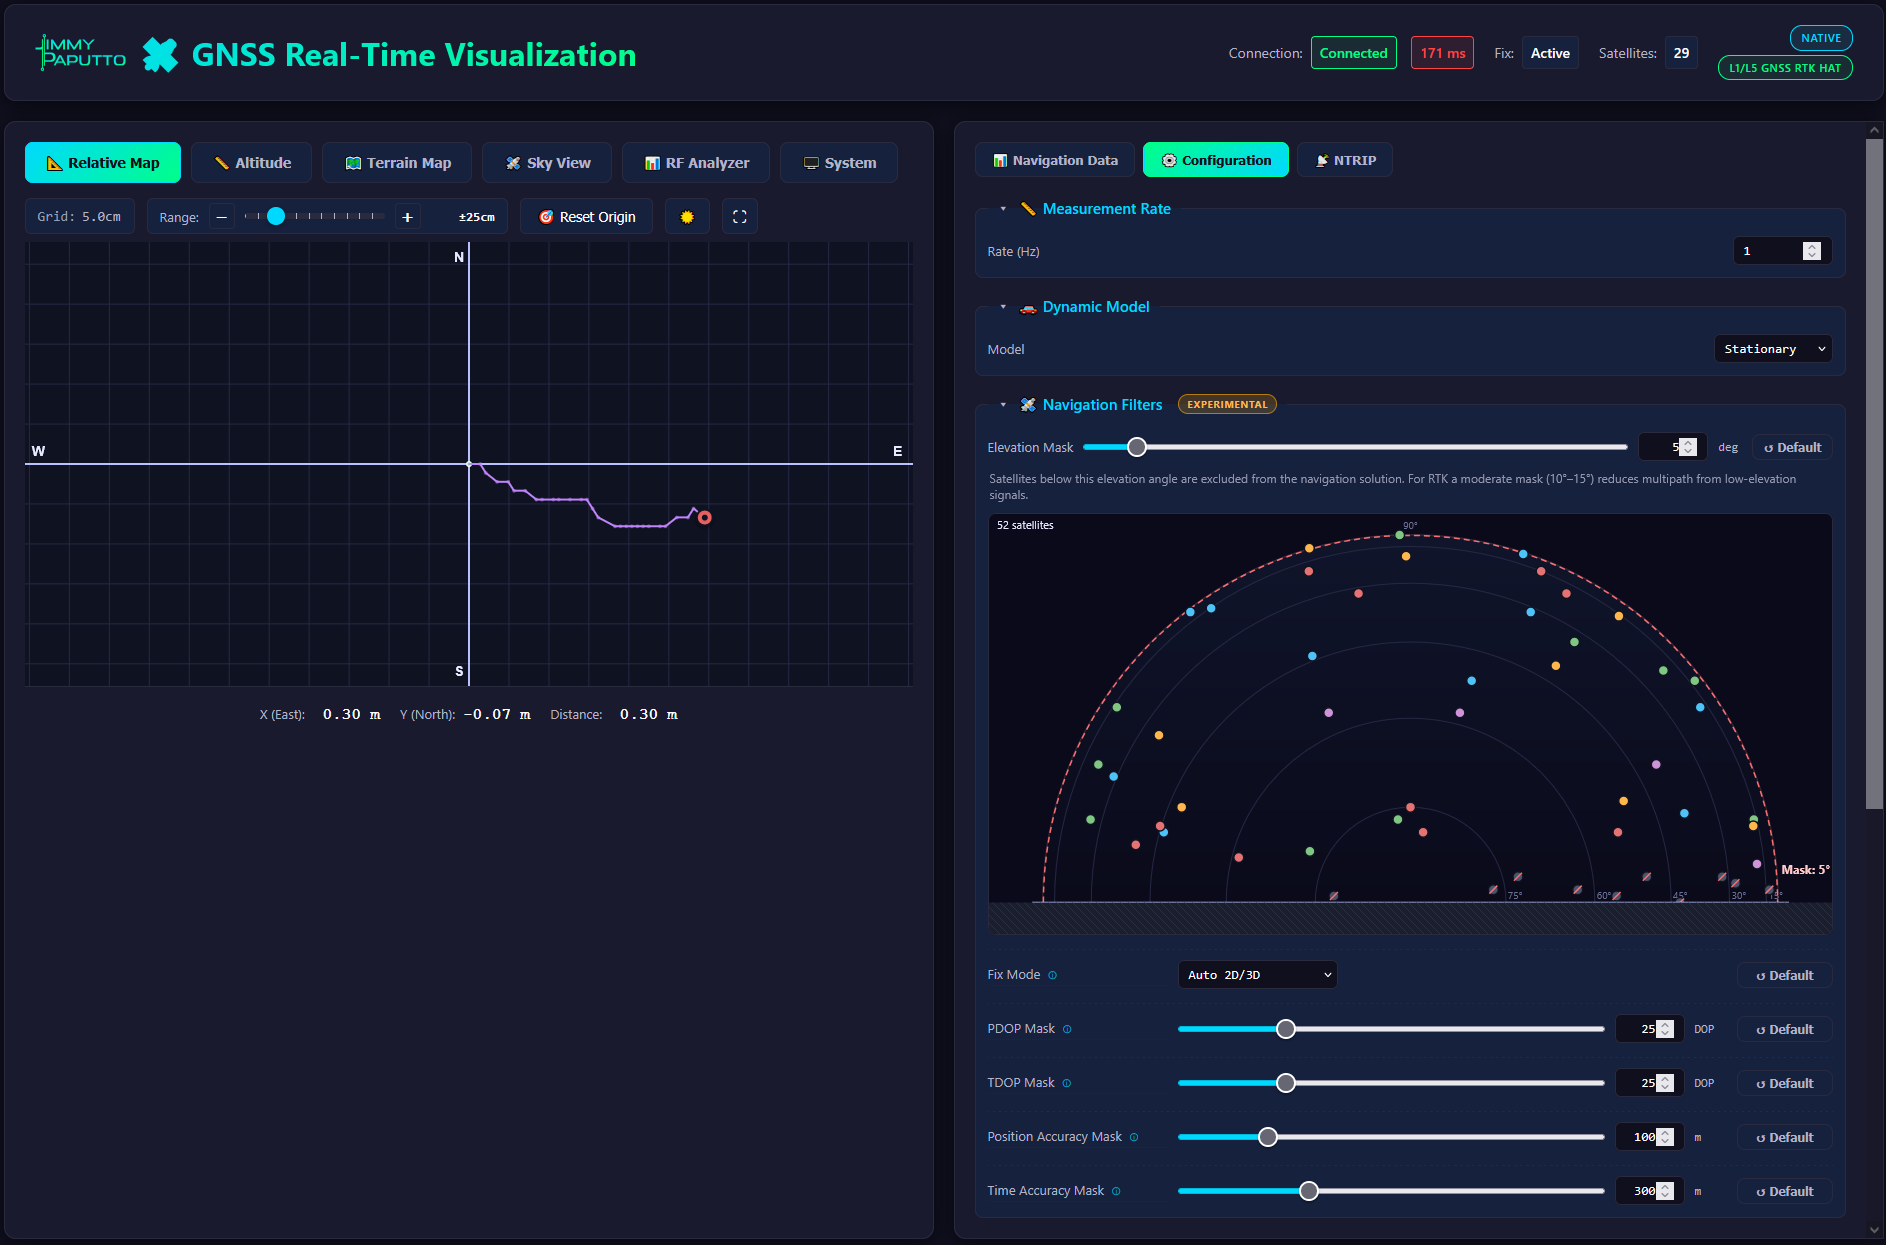
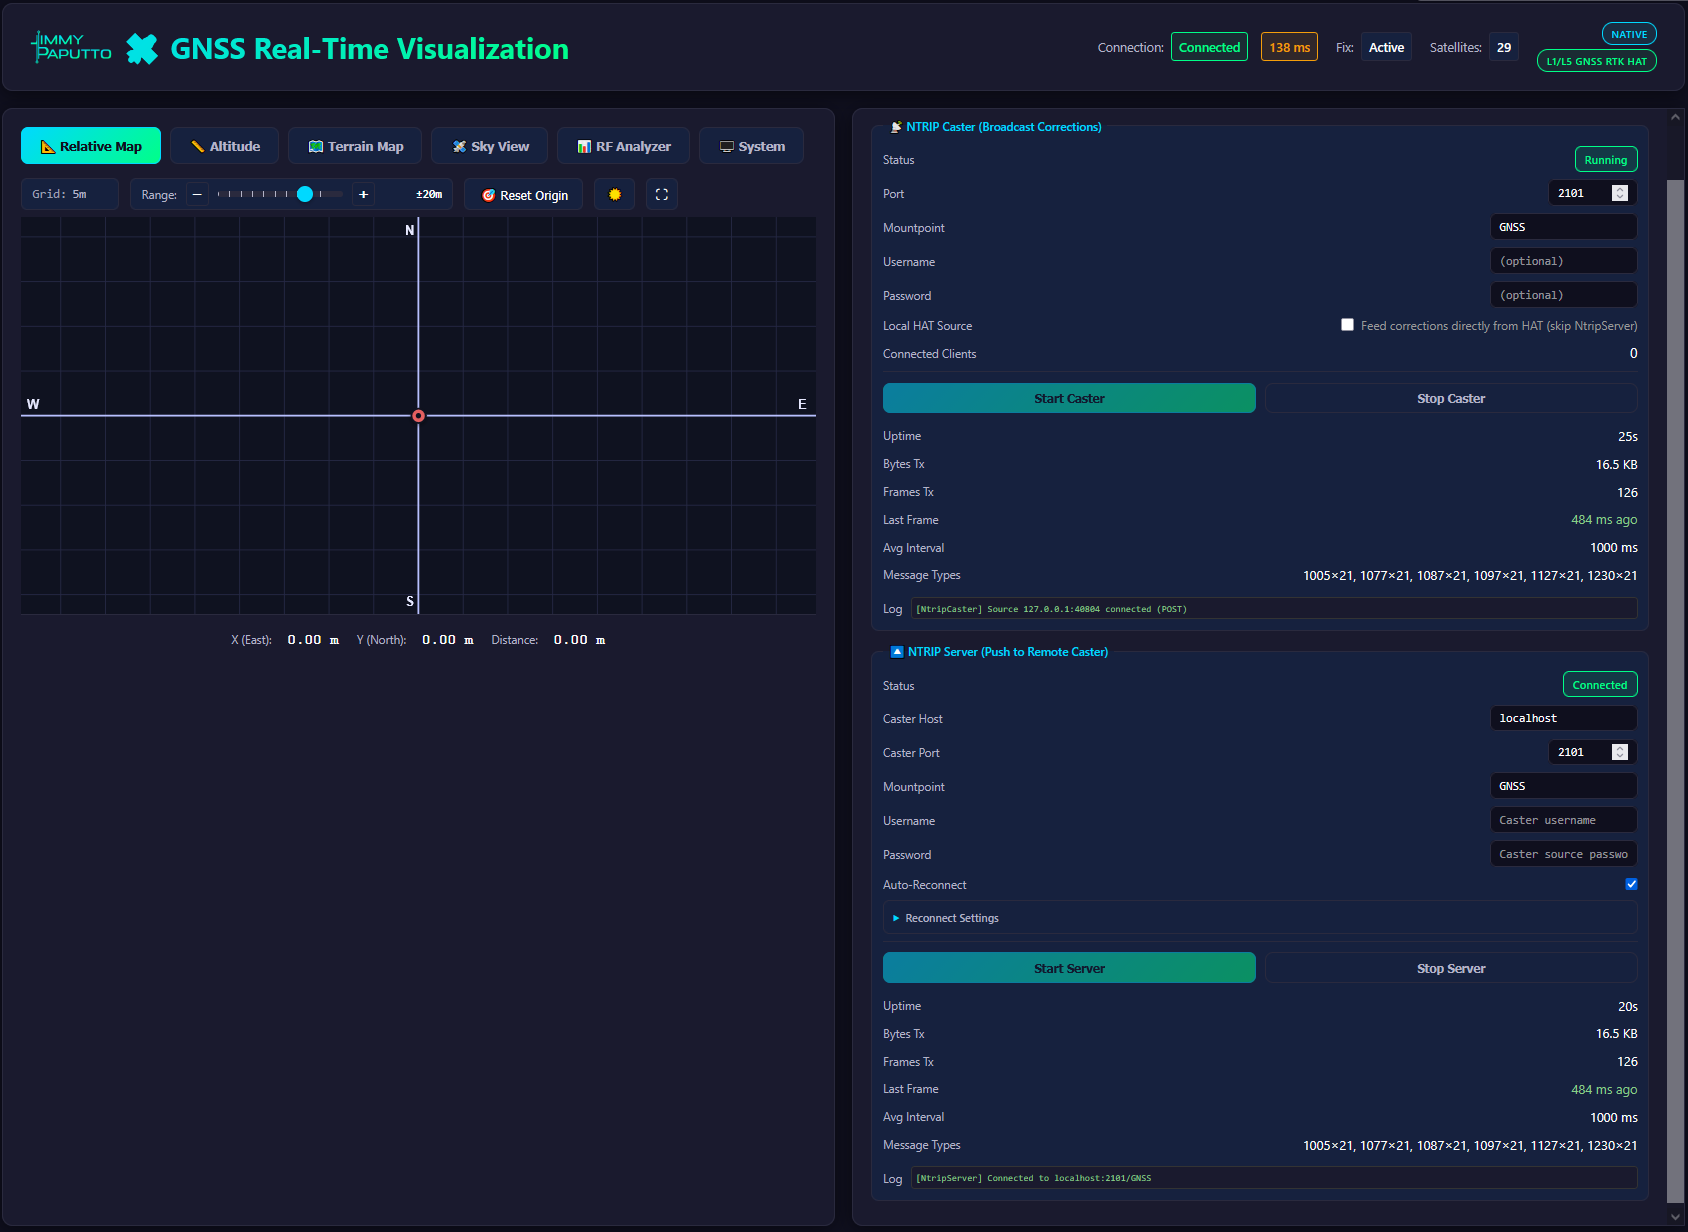
- Visualisation UI App check out features instantly, don’t waste your time for complex setup, dowload, install and check if given feature suites you
Quick Links
- Installation - build and install the library
- Getting the position - get your first position fix in minutes
- Choose Your Path - jump to RTK, timing, geofencing, or integration work
- RTK - prepare a basic setup for base and rover in just few clicks
- C++ API · C API · Python API - full API reference
- Examples - annotated code for every feature
- Troubleshooting - common issues and fixes
Visualisation App
You can review most of the features in the visualisation app. Don’t waste your time on preparing own samples and benchmarks - see the Visualisation App page for all the screens.